Resources
Application engineering, customization strategy, and integration guidance for industrial OEM products and assemblies.
Use this category to review practical procurement and engineering patterns. Each article is written to reduce ambiguity in RFQ, validation, and production release decisions.
Instead of generic theory, these posts focus on what buyers can send, measure, and approve in supplier communication.
In practical sourcing programs, this category is most useful when its article checklists are copied into internal review templates and then reused in supplier calls, sample sign-off notes, and PO release approvals.
These articles are sorted by publish date and are intended to be used as reusable inputs for your engineering and procurement handoffs.
| Article | Primary Use | Next Step |
|---|---|---|
| Joint Torque Sensors in Custom Humanoid Actuators: Strain-Gauge Flanges, Cross-Axis Moment Rejection, Force Control Bandwidth, and Sourcing Acceptance Protocols | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Hollow-Shaft Cable Routing in Custom Humanoid Actuators: Bore Sizing, Torsion Fatigue Life, Multi-Conductor EMI Shielding, and Sourcing Acceptance Protocols | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Integrated Servo Drives in Custom Humanoid Actuators: GaN vs. Silicon Inverters, Communication Bus Latency, Thermal Segregation, and PCBA Sourcing Acceptance | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Crossed Roller Bearings in Custom Humanoid Actuators: Moment Rigidity, Preload Sizing, Dynamic Shock Tolerance, and Sourcing Acceptance Protocols | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Spring-Applied Holding Brakes in Custom Humanoid Actuators: Power-Off Posture Retention, Overexcitation Thermal Budgets, and RFQ Acceptance Protocols | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Dual-Encoder Architecture in Humanoid Joint Actuators: Link-Side vs. Motor-Side Sensing, Elastic Deflection Compensation, and RFQ Acceptance Protocols | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Inverted Planetary Roller Screws vs. Ball Screws in Humanoid Linear Actuators: Sourcing, Dynamic Load, and Life-Cycle Engineering | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Custom Humanoid Actuator BOM Integration and Sourcing Guide | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Humanoid Actuator Backlash Testing: RFQ Guide for Custom Reducers | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| QDD (Quasi-Direct Drive) Actuator Design for Bipedal Humanoid Legs | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Thermal Derating in Custom Humanoid Actuators | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Harmonic vs. Cycloidal Drives in Custom Humanoid Actuators | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
| Custom Humanoid Actuator ODM RFQ Guide | Buyer-side decision and supplier communication alignment. | Convert checklist items into your RFQ or sample plan. |
Need project-specific guidance? Start from Contact / RFQ and include the article links your team is referencing.
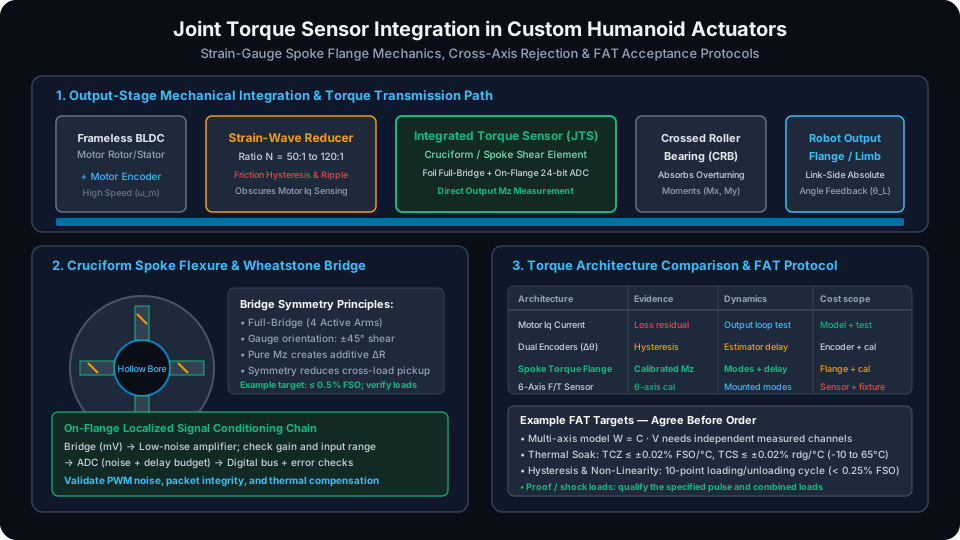
Compare joint torque sensors for humanoid actuators: spoke strain-gauge flanges, cross-axis rejection, force bandwidth, and FAT calibration. Request an RFQ.
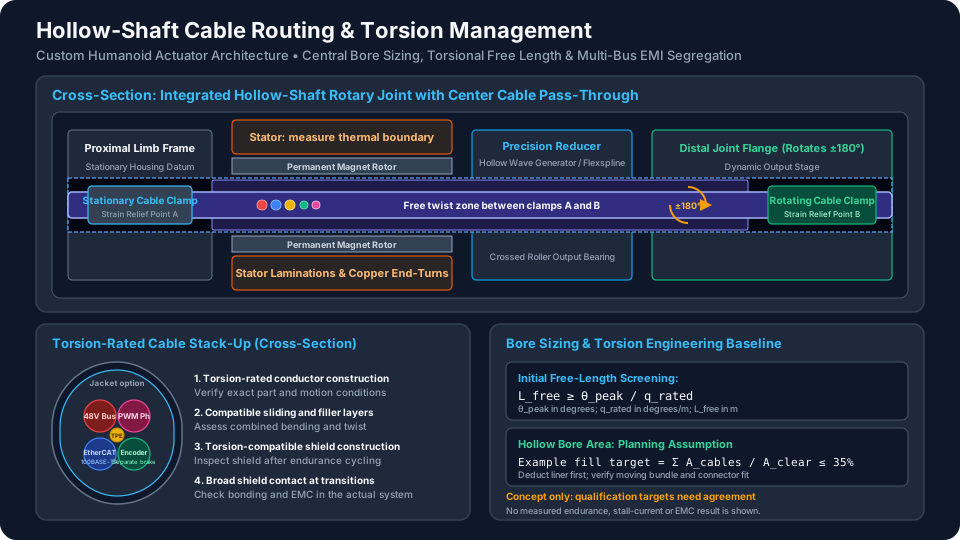
Master hollow-shaft cable routing for humanoid actuators: bore sizing, torsion fatigue limits, EtherCAT/phase EMI shielding, and supplier RFQ acceptance.
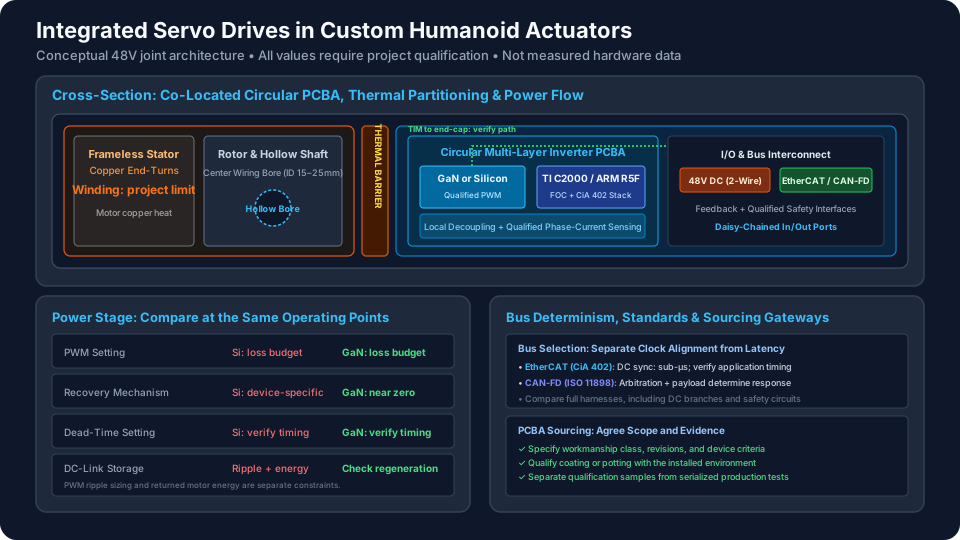
Compare integrated servo drives for humanoid actuators: GaN vs. silicon, bus latency, thermal limits, and PCBA acceptance. Prepare an engineering RFQ checklist.
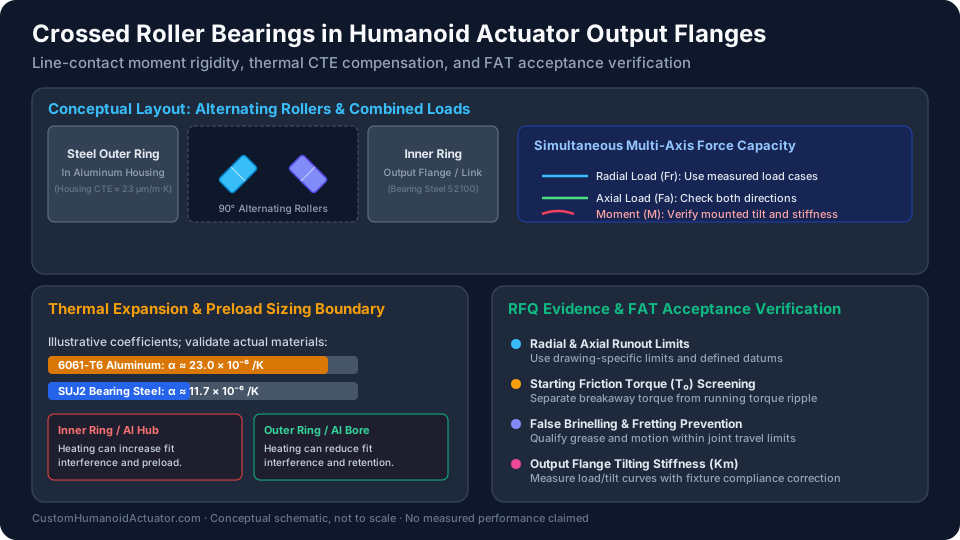
Compare crossed roller bearings for humanoid actuators: moment rigidity, thermal fits, shock loads, and supplier acceptance checks. Prepare your bearing RFQ.
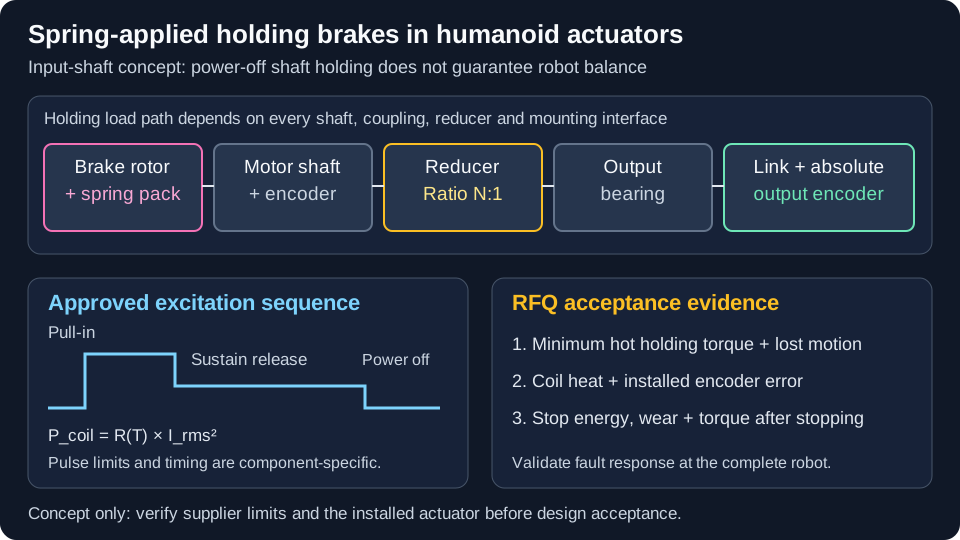
Specify spring-applied holding brakes for your custom humanoid actuator: compare power-off retention, thermal budgets, and FAT evidence before sending an RFQ.
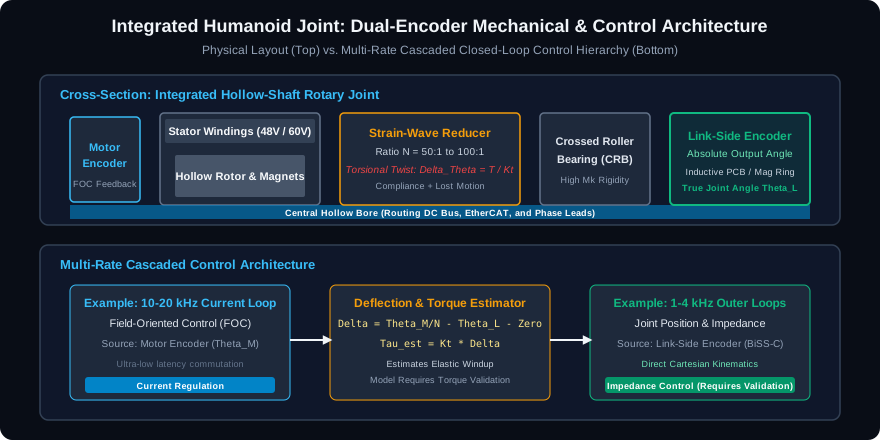
Compare dual-encoder architecture for humanoid joints: motor vs link sensing, torque-estimation limits and calibration tests. Prepare an actuator RFQ.